All projects
Course project · Intelligent Robot Crash Lab · 2020
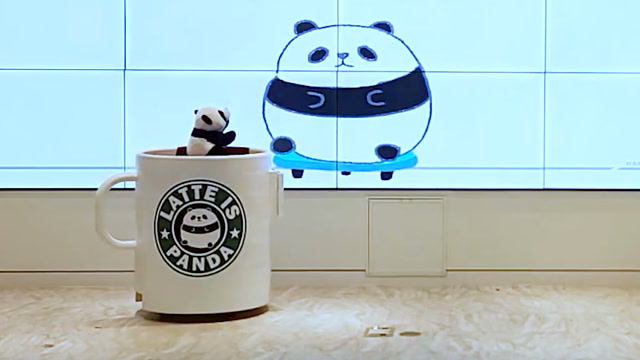
Latte Panda: a mobile robot that sorts cups and collects donations
Latte Panda is a service robot for public recycling. It finds a person holding a disposable cup, sorts the cup into a paper or plastic bin, and invites a donation through a QR code.
- Team
- 6 students
- Compute
- LattePanda Alpha, Jetson TX2, Arduino Mega
- Sensors
- RealSense D435, touchscreen
- Stack
- ROS, C++, YOLOv5, TensorRT, PyQt
What a visit looks like
- 1 Approach The robot drives around, finds a person and greets them with a motion and a short introduction.
- 2 Sort It asks for a disposable cup, recognizes it as paper or plastic, and tilts the matching bin open.
- 3 Donate The touchscreen offers a donation by QR code and plays a thank-you video.
The system
DetectionColor frames go to a YOLO server, which sends them to the Jetson TX2 with a mode: find people, classify a cup as paper or plastic, or read a hand sign. YOLOv5 ran on the TX2 with TensorRT.
Obstacle avoidanceThe 640×480 depth image is low-pass filtered, averaged over 20 frames and split into a 3×5 grid. The nearest distance in each cell, weighted by a sigmoid, sets the left and right wheel speeds.
Following a personBearing comes from the horizontal position of the detection; distance is the mean depth over a 100×100 window at its center.
ActuationDynamixel motors play the robot's greeting motions and tilt the bins; an Arduino Mega runs the drive motors with PID control over rosserial.
My part
On a team of six I worked on the system design, motor control, communication, sensor control, the algorithms, the electrical system and the UI.